Autonomous navigation
ROS-based navigation (NAV2) lets the robot map the space, patrol set routes, and lead visitors from A to B on its own - no rails, no operator driving it.
An autonomous indoor guide robot with a voice-driven 3D-avatar interface, built for an advanced-technology learning, innovation, and demonstration centre in Abu Dhabi. It patrols mapped routes and self-charges on its own, while visitors ask for directions, facility info, and programme details and the bot replies by voice through a lip-synced 3D avatar.
Tap SPEAK, ask a question, and the lip-synced 3D avatar answers out loud - the same screen visitors meet at the centre.
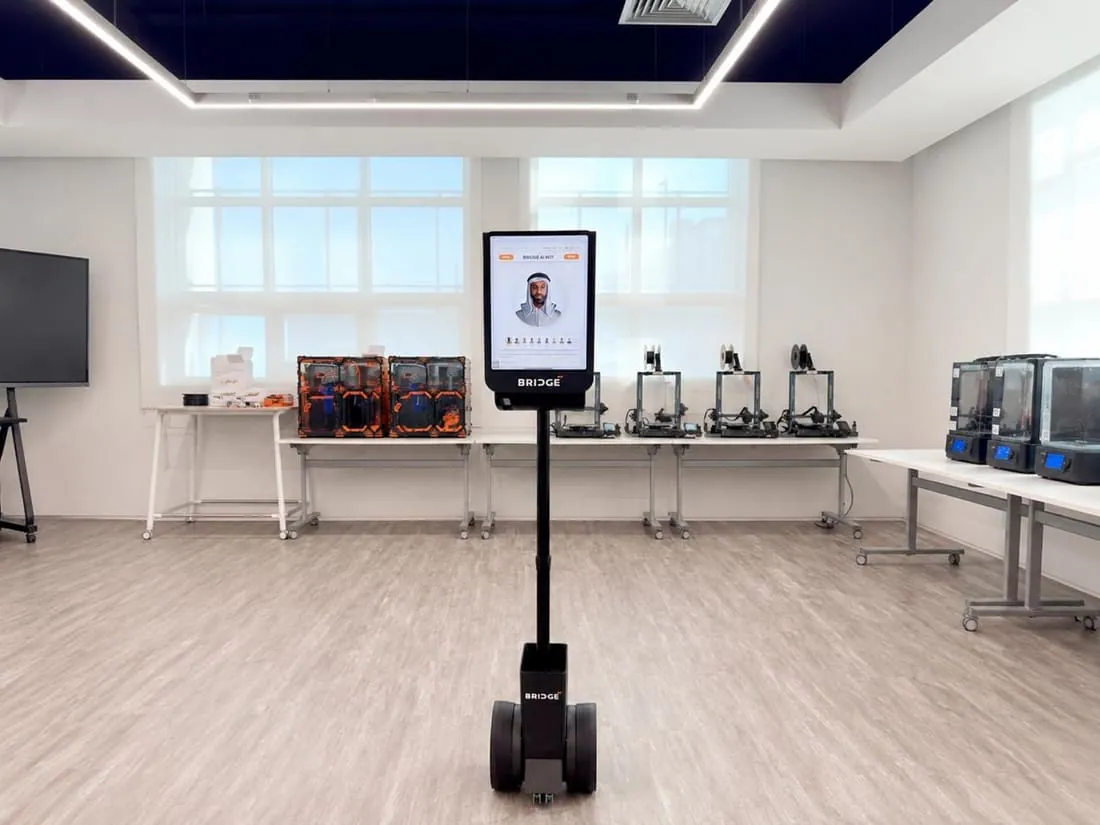
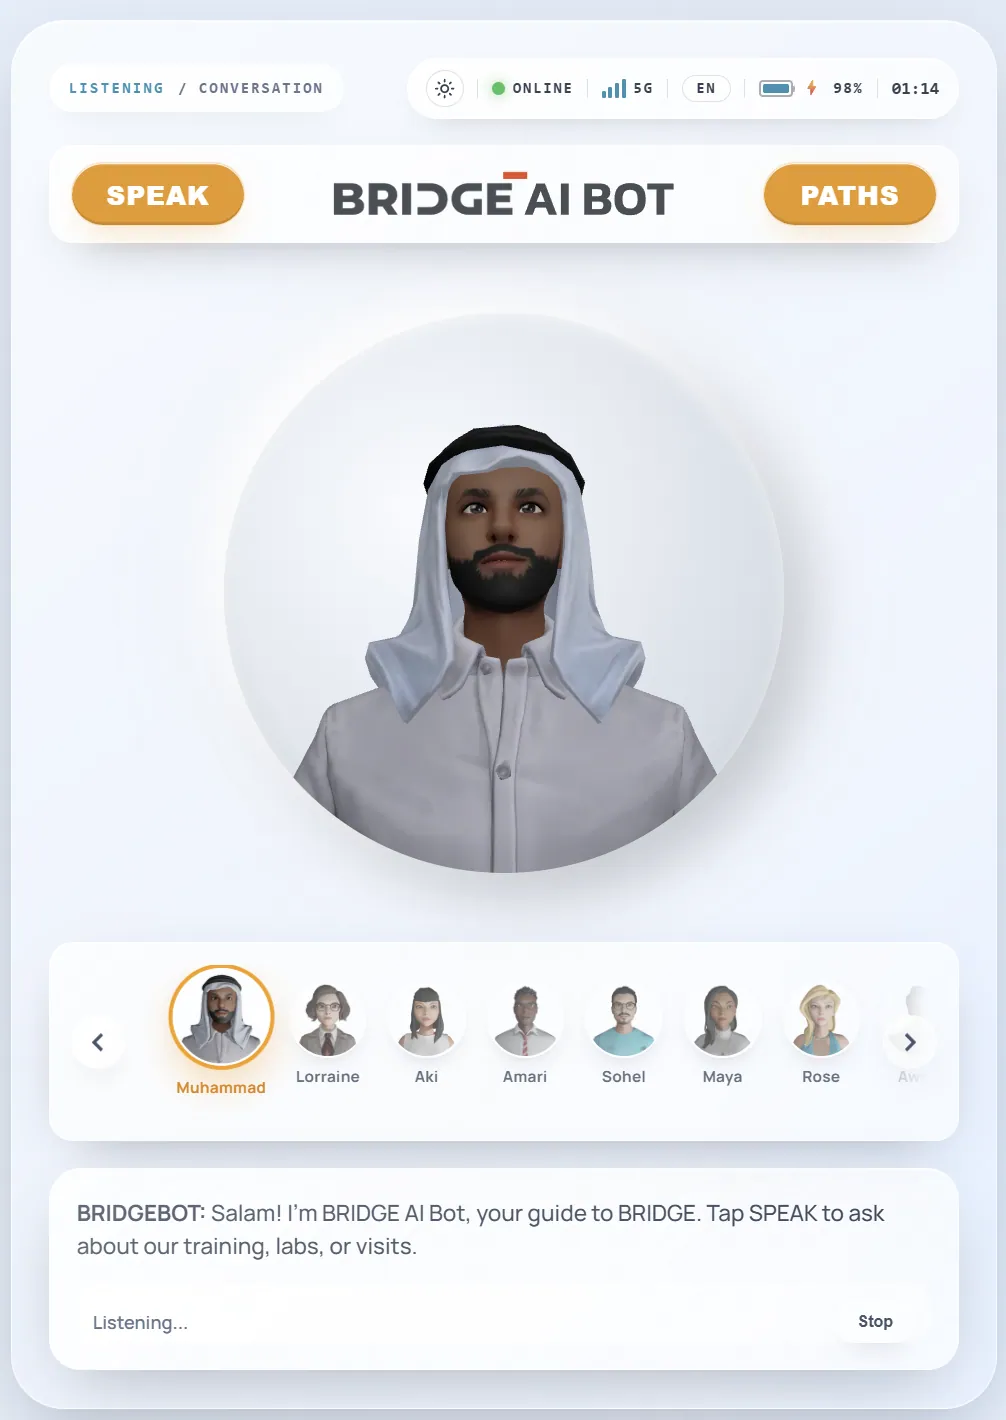
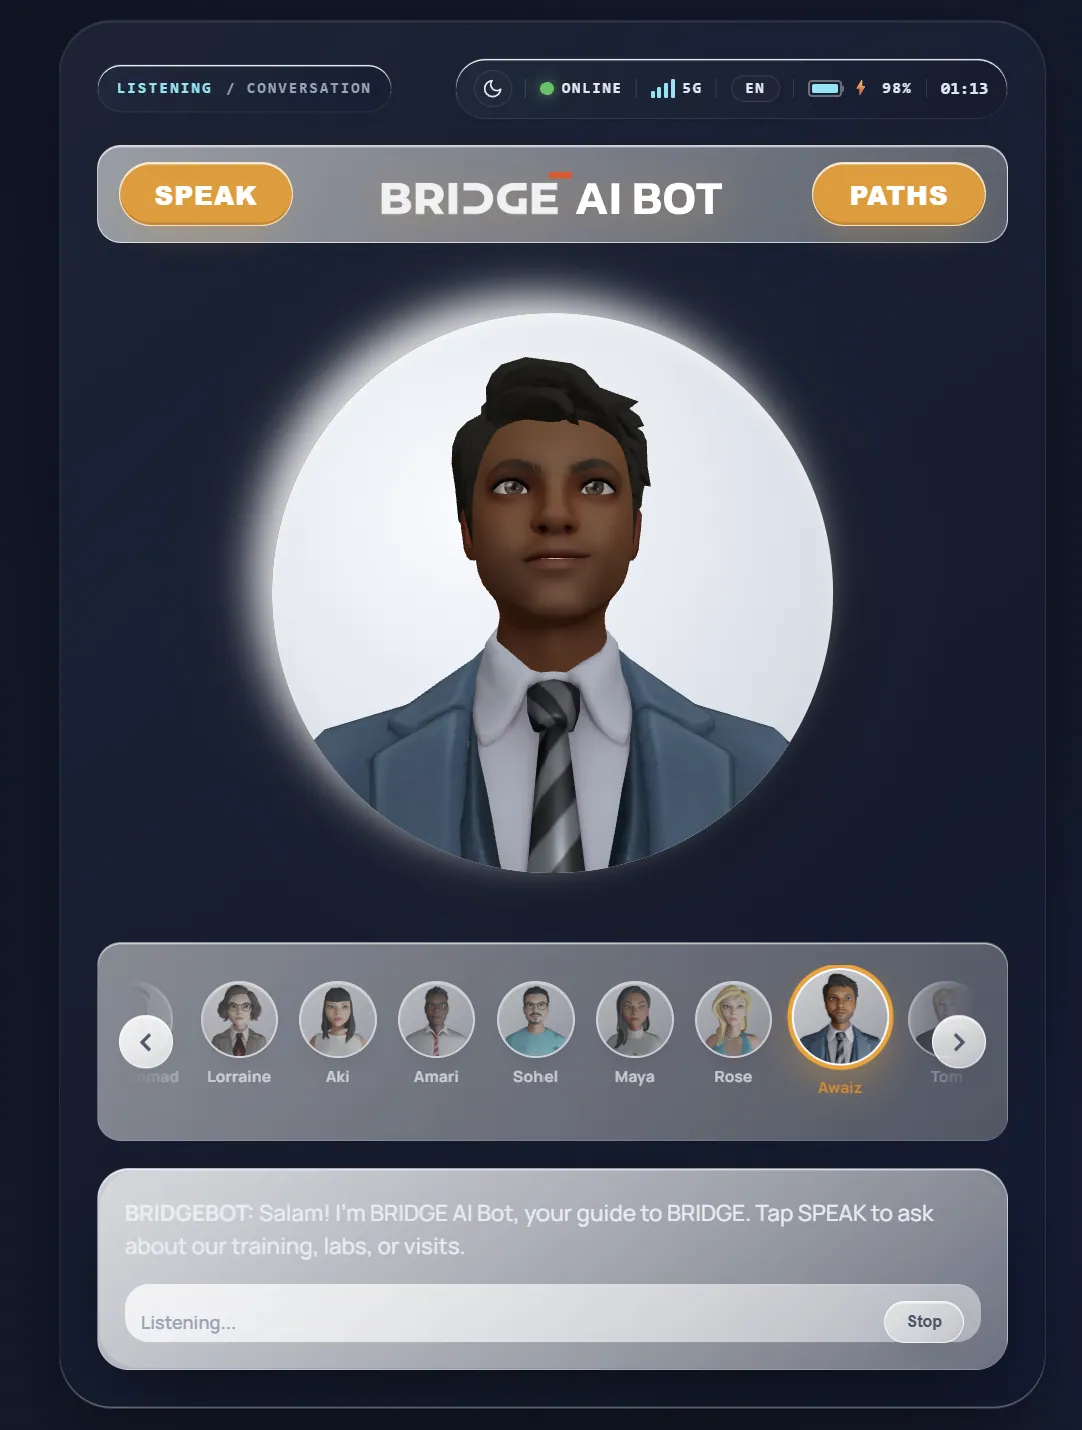
Directions, facilities, and programmes - Lean, Six Sigma, Lean Digital, Agile, Data Analytics, IoT, CEO 4.0, the Engineering Bootcamp, and more - answered out loud by a 3D avatar, and the robot can lead visitors there on mapped routes.
ROS-based navigation (NAV2) lets the robot map the space, patrol set routes, and lead visitors from A to B on its own - no rails, no operator driving it.
When the battery runs low the robot returns to its dock and recharges itself, so it stays on the floor and ready without anyone plugging it in.
A muhammad.glb avatar rendered with Three.js speaks each reply with synced lip movement, so visitors talk to a face, not a text box.
SpeechRecognition takes the visitor's question and text-to-speech reads the answer aloud - fully hands-free at the kiosk.
A local faqs.json knowledge base answers directions (VIP room, offices, classrooms) and facility questions instantly, with no round-trip.
Anything not matched locally falls through to OpenAI (gpt-4o-mini), proxied through the backend so the API key stays server-side.
An autonomous indoor guide robot: ROS navigation and self-charging on mapped routes, with a voice-driven 3D avatar answering visitor questions through an LLM.